projects / iris
Iris
Kernel and OS
- A custom Linux kernel and board support package for a Radxa board. They are forks of
radxa/kernel,radxa-repo/bsp, and the RadxaOSrsdk. - A reproducible OS image build.
- A package repository of pre-built binaries, so a team can install and update with no internet at a competition.
Vision pipeline
- Python. AprilTag3 through my own fork of
pyapriltags, updated to 3.4.3 with wheel builds. ArUco detectors are also supported. - Multi-tag Perspective-n-Point pose estimation with RANSAC outlier rejection.
- Per-tag transforms, and a configurable list of tag IDs to ignore.
- Camera calibration through mrcal, with visualizations.
Robot integration
- Results are encoded as WPIStructs and published to NetworkTables.
- A Java vendordep reads them in robot code.
- The WPILib field layout JSON is used directly, so a new game works on kickoff day.
Logging and tools
- MCAP logs with Protocol Buffers and JPEG frames, viewable in Foxglove Studio. Logs are numbered sequentially so they survive clock resets.
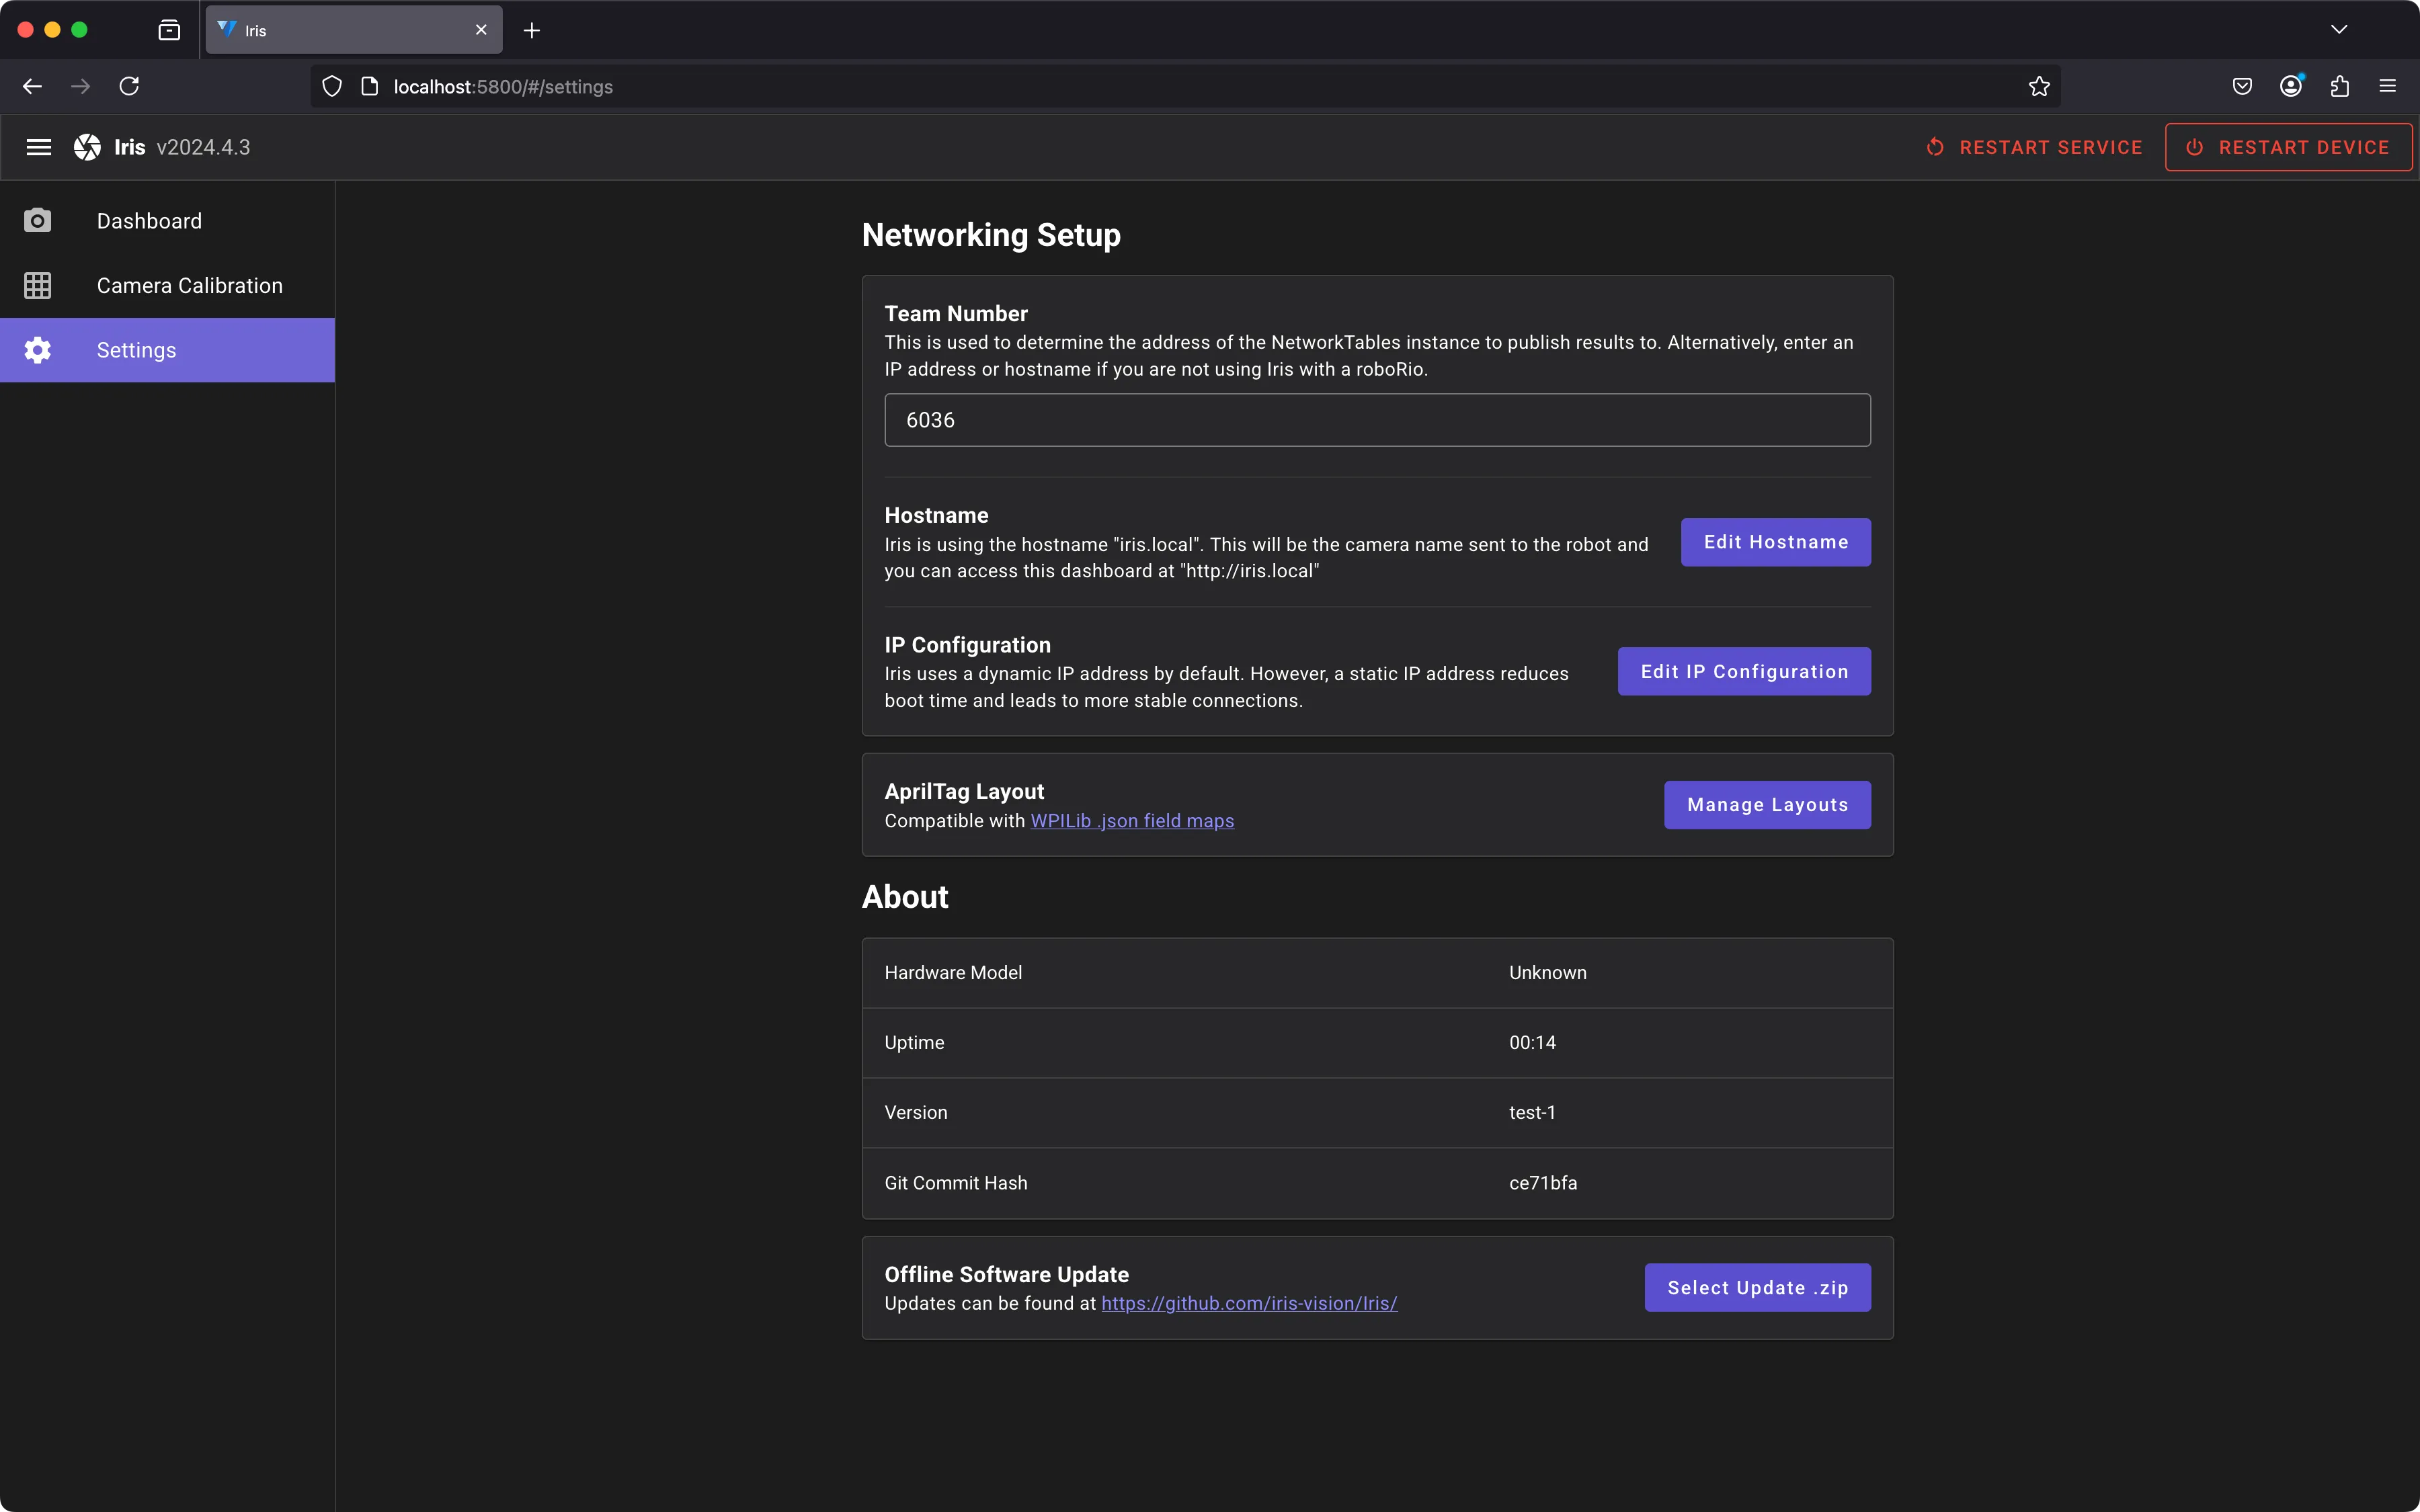
- A web dashboard for live camera streams and tuning.
Media
Match replay demo with four cameras on YouTube.
Outcome
Iris ran on Team 6036’s robot in competition. We developed it as a potential product and shelved it after evaluating the market.